
Chapter 10
Advanced Maneuvers
The altitude at completion should be no higher than the maximum safe hovering altitude prescribed by the manufacturer. In selecting an altitude at which to begin the maneuver, you should take into account the overall length of the helicopter and the height/velocity diagram.
Even though the maneuver is called a rapid deceleration or quick stop, it is performed slowly and smoothly with the primary emphasis on coordination.
Technique
During training always perform this maneuver into the wind. [Figure 10-3, position 1] After leveling off at an altitude between 25 and 40 feet, depending on the manufacturer’s recommendations, accelerate to the desired entry speed, which is approximately 45 knots for most training helicopters (position 2). The altitude you choose should be high enough to avoid danger to the tail rotor during the flare, but low enough to stay out of the crosshatched or shaded areas of the height/velocity diagram throughout the maneuver. In addition, this altitude should be low enough that you can bring the helicopter to a hover during the recovery.
At position 3, initiate the deceleration by applying aft cyclic to reduce forward speed. Simultaneously, lower the collective, as necessary, to counteract any climbing tendency. The timing must be exact. If you apply too little down collective for the amount of aft cyclic applied, a climb results. If you apply too much down collective, a descent results. A rapid application of aft cyclic requires an equally rapid application of down collective. As collective pitch is lowered, apply proper antitorque pedal pressure to maintain heading, and adjust the throttle to maintain r.p.m.
After attaining the desired speed (position 4), initiate the recovery by lowering the nose and allowing the helicopter to descend to a normal hovering altitude in level flight and zero groundspeed (position 5). During the recovery, increase collective pitch, as necessary, to stop the helicopter at normal hovering altitude, adjust the throttle to maintain r.p.m., and apply proper pedal pressure, as necessary, to maintain heading.
Common Errors
- Initiating the maneuver by applying down collective.
- Initially applying aft cyclic stick too rapidly, causing the helicopter to balloon.
- Failing to effectively control the rate of deceleration to accomplish the desired results.
- Allowing the helicopter to stop forward motion in a tail-low attitude.
- Failing to maintain proper r.p.m.
- Waiting too long to apply collective pitch (power) during the recovery, resulting in excessive manifold pressure or an over-torque situation when collective pitch is applied rapidly.
- Failing to maintain a safe clearance over the terrain.
- Improper use of antitorque pedals resulting in erratic heading changes.
Steep Approach to a Hover
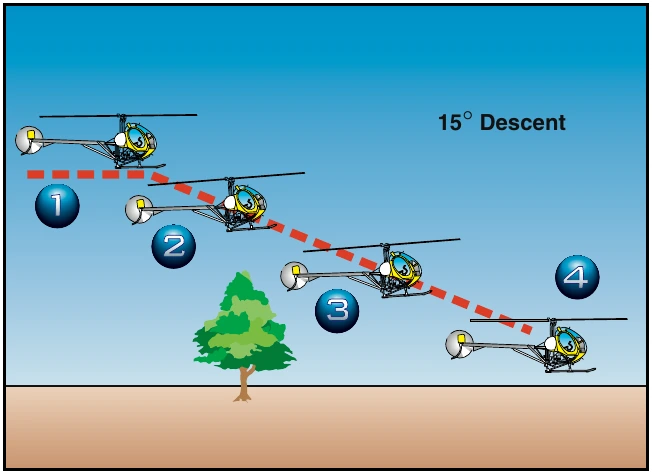
A steep approach is used primarily when there are obstacles in the approach path that are too high to allow a normal approach. A steep approach permits entry into most confined areas and is sometimes used to avoid areas of turbulence around a pinnacle. An approach angle of approximately 15° is considered a steep approach. [Figure 10-4]
Technique
On final approach, head your helicopter into the wind and align it with the intended touchdown point at the recommended approach airspeed (position 1). When you intercept an approach angle of 15°, begin the approach by lowering the collective sufficiently to start the helicopter descending down the approach path and decelerating (position 2). Use the proper antitorque pedal for trim. Since this angle is steeper than a normal approach angle, you need to reduce the collective more than that required for a normal approach. Continue to decelerate with slight aft cyclic, and smoothly lower the collective to maintain the approach angle. As in a normal approach, reference the touchdown point on the windshield to determine changes in approach angle. This point is in a lower position than a normal approach. Aft cyclic is required to decelerate sooner than a normal approach, and the rate of closure becomes apparent at a higher altitude. Maintain the approach angle and rate of descent with the collective, rate of closure with the cyclic, and trim with antitorque pedals. Use a crab above 50 feet and a slip below 50 feet for any crosswind that might be present.
Loss of effective translational lift occurs higher in a steep approach (position 3), requiring an increase in the collective to prevent settling, and more forward cyclic to achieve the proper rate of closure. Terminate the approach at hovering altitude above the intended landing point with zero groundspeed (position 4). If power has been properly applied during the final portion of the approach, very little additional power is required in the hover.
Balloon— Gaining an excessive amount of altitude as a result of an abrupt flare.
Common Errors
- Failing to maintain proper r.p.m. during the entire approach.
- Improper use of collective in maintaining the selected angle of descent.
- Failing to make antitorque pedal corrections to compensate for collective pitch changes during the approach.
- Slowing airspeed excessively in order to remain on the proper angle of descent.
- Inability to determine when effective translational lift is lost.
- Failing to arrive at hovering altitude and attitude, and zero groundspeed almost simultaneously.
- Low r.p.m. in transition to the hover at the end of the approach.
- Using too much aft cyclic close to the surface, which may result in the tail rotor striking the surface.
Shallow Approach and Running/Roll-On Landing
Use a shallow approach and running landing when a high-density altitude or a high gross weight condition, or some combination thereof, is such that a normal or steep approach cannot be made because of insufficient power to hover. [Figure 10-5] To compensate for this lack of power, a shallow approach and running landing makes use of translational lift until surface contact is made. If flying a wheeled helicopter, you can also use a roll-on landing to minimize the effect of downwash.
The glide angle for a shallow approach is approximately 5°. Since the helicopter will be sliding or rolling to a stop during this maneuver, the landing area must be smooth and long enough to accomplish this task.