
Chapter 2
Aerodynamics, Aircraft Assembly, & Rigging
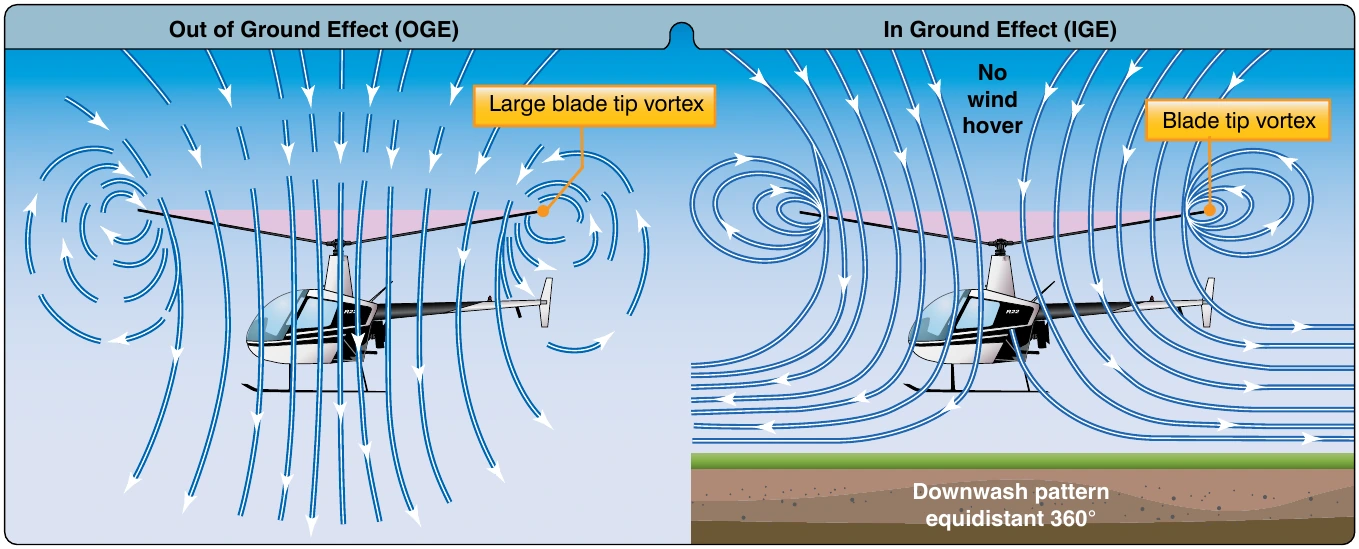
Ground effect is at its maximum in a no-wind condition over a firm, smooth surface. Tall grass, rough terrain, and water surfaces alter the airflow pattern, causing an increase in rotor tip vortices. [Figure 2-33]
Coriolis Effect (Law of Conservation of Angular Momentum)
The Coriolis effect is also referred to as the law of conservation of angular momentum. It states that the value of angular momentum of a rotating body does not change unless an external force is applied. In other words, a rotating body continues to rotate with the same rotational velocity until some external force is applied to change the speed of rotation. Angular momentum is moment of inertia (mass times distance from the center of rotation squared) multiplied by speed of rotation. Changes in angular velocity, known as angular acceleration and deceleration, take place as the mass of a rotating body is moved closer to or further away from the axis of rotation. The speed of the rotating mass increases or decreases in proportion to the square of the radius. An excellent example of this principle is a spinning ice skater. The skater begins rotation on one foot, with the other leg and both arms extended. The rotation of the skater’s body is relatively slow. When a skater draws both arms and one leg inward, the moment of inertia (mass times radius squared) becomes much smaller and the body is rotating almost faster than the eye can follow. Because the angular momentum must remain constant (no external force applied), the angular velocity must increase. The rotor blade rotating about the rotor hub possesses angular momentum. As the rotor begins to cone due to G-loading maneuvers, the diameter or the disc shrinks. Due to conservation of angular momentum, the blades continue to travel the same speed even though the blade tips have a shorter distance to travel due to reduced disc diameter. The action results in an increase in rotor rpm. Most pilots arrest this increase with an increase in collective pitch. Conversely, as G-loading subsides and the rotor disc flattens out from the loss of G-load induced coning, the blade tips now have a longer distance to travel at the same tip speed. This action results in a reduction of rotor rpm. However, if this drop in the rotor rpm continues to the point at which it attempts to decrease below normal operating rpm, the engine control system adds more fuel/power to maintain the specified engine rpm. If the pilot does not reduce collective pitch as the disc unloads, the combination of engine compensation for the rpm slow down and the additional pitch as G-loading increases may result in exceeding the torque limitations or power the engines can produce.
Vertical Flight
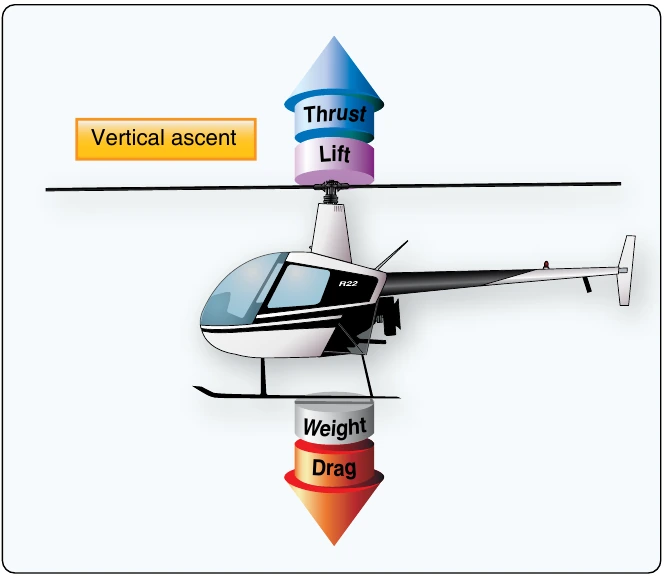
Hovering is actually an element of vertical flight. Increasing the AOA of the rotor blades (pitch) while keeping their rotation speed constant generates additional lift and the helicopter ascends. Decreasing the pitch causes the helicopter to descend. In a no wind condition, when lift and thrust are less than weight and drag, the helicopter descends vertically. If lift and thrust are greater than weight and drag, the helicopter ascends vertically. [Figure 2-34]
Forward Flight
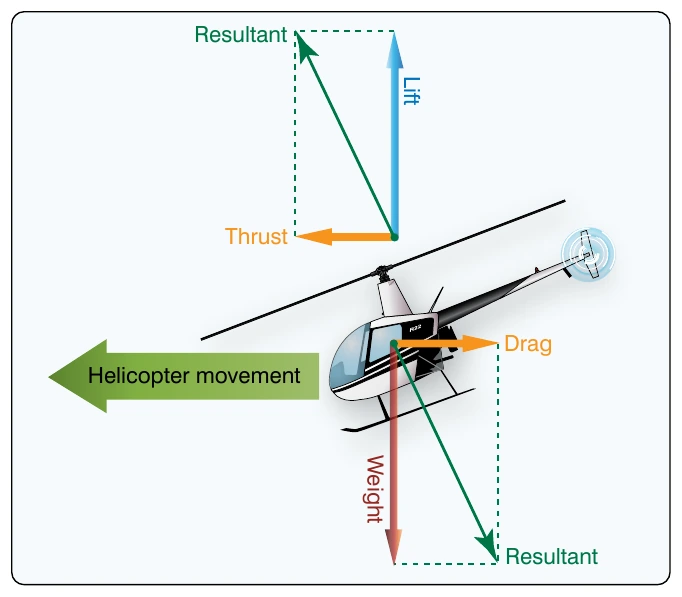
In steady forward flight with no change in airspeed or vertical speed, the four forces of lift, thrust, drag, and weight must be in balance. Once the tip-path plane is tilted forward, the total lift-thrust force is also tilted forward. This resultant lift-thrust force can be resolved into two components—lift acting vertically upward and thrust acting horizontally in the direction of flight. In addition to lift and thrust, there is weight (the downward acting force) and drag (the force opposing the motion of an airfoil through the air). [Figure 2-35]
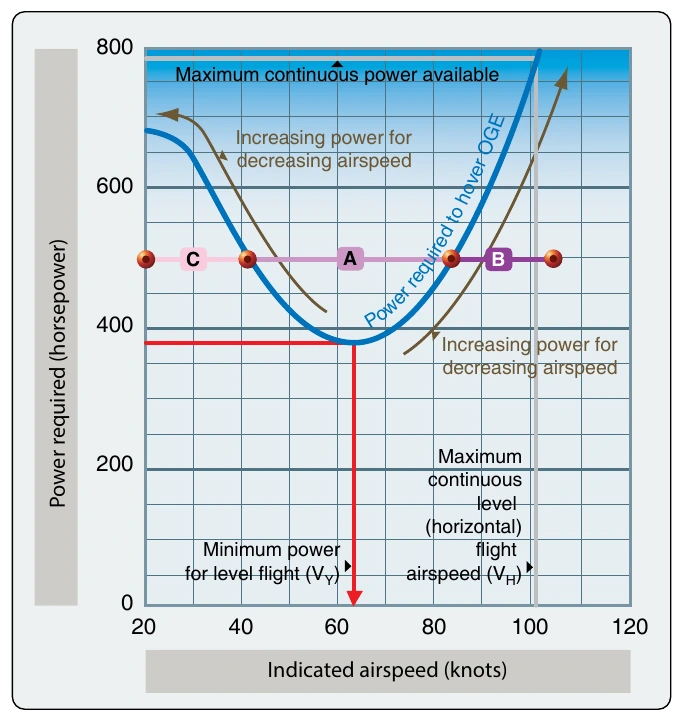
In straight-and-level (constant heading and at a constant altitude), unaccelerated forward flight, lift equals weight and thrust equals drag. If lift exceeds weight, the helicopter accelerates vertically until the forces are in balance; if thrust is less than drag, the helicopter slows until the forces are in balance. As the helicopter moves forward, it begins to lose altitude because lift is lost as thrust is diverted forward. However, as the helicopter begins to accelerate, the rotor system becomes more efficient due to the increased airflow. The result is excess power over that which is required to hover. Continued acceleration causes an even larger increase in airflow through the rotor disc and more excess power. In order to maintain unaccelerated flight, the pilot must not make any changes in power or in cyclic movement. Any such changes would cause the helicopter to climb or descend. Once straight-and-level flight is obtained, the pilot should make note of the power (torque setting) required and not make major adjustments to the flight controls. [Figure 2-36]
Translational Lift
Improved rotor efficiency resulting from directional flight is called translational lift. The efficiency of the hovering rotor system is greatly improved with each knot of incoming wind gained by horizontal movement of the aircraft or surface wind. As incoming wind produced by aircraft movement or surface wind enters the rotor system, turbulence and vortices are left behind and the flow of air becomes more horizontal. In addition, the tail rotor becomes more aerodynamically efficient during the transition from hover to forward flight. Translational thrust occurs when the tail rotor becomes more aerodynamically efficient during the transition from hover to forward flight. As the tail rotor works in progressively less turbulent air, this improved efficiency produces more antitorque thrust, causing the nose of the aircraft to yaw left (with a main rotor turning counterclockwise) and forces the pilot to apply right pedal (decreasing the AOA in the tail rotor blades) in response. In addition, during this period, the airflow affects the horizontal components of the stabilizer found on most helicopters which tends to bring the nose of the helicopter to a more level attitude. Figure 2-37 and Figure 2-38 show airflow patterns at different speeds and how airflow affects the efficiency of the tail rotor.
Effective Translational Lift (ETL)
While transitioning to forward flight at about 16–24 knots, the helicopter experiences effective translational lift (ETL). As mentioned earlier in the discussion on translational lift, the rotor blades become more efficient as forward airspeed increases. Between 16–24 knots, the rotor system completely outruns the recirculation of old vortices and begins to work in relatively undisturbed air. The flow of air through the rotor system is more horizontal, therefore induced flow and induced drag are reduced. The AOA is subsequently increased, which makes the rotor system operate more efficiently. This increased efficiency continues with increased airspeed until the best climb airspeed is reached, and total drag is at its lowest point.
As speed increases, translational lift becomes more effective, the nose rises or pitches up, and the aircraft rolls to the right. The combined effects of dissymmetry of lift, gyroscopic precession, and transverse flow effect cause this tendency. It is important to understand these effects and anticipate correcting for them. Once the helicopter is transitioning through ETL, the pilot needs to apply forward and left lateral cyclic input to maintain a constant rotor-disc attitude. [Figure 2-39]
Dissymmetry of Lift
Dissymmetry of lift is the differential (unequal) lift between advancing and retreating halves of the rotor disc caused by the different wind flow velocity across each half. This difference in lift would cause the helicopter to be uncontrollable in any situation other than hovering in a calm wind. There must be a means of compensating, correcting, or eliminating this unequal lift to attain symmetry of lift.